I’m a robotics and machine learning engineer in San Francisco.
I’ve trained robots to fold cloth and deployed reinforcement learning models in production.
Selected work Sim-to-real · separate runs Play ↗ Robot learning · IROS 2022
Training a visual feedback policy in simulation and transferring it to a real robot. The project includes camera latency measurements, a shared C++ controller, and cloth dynamics randomization.
First-author paper. IROS Best Paper Award finalist.
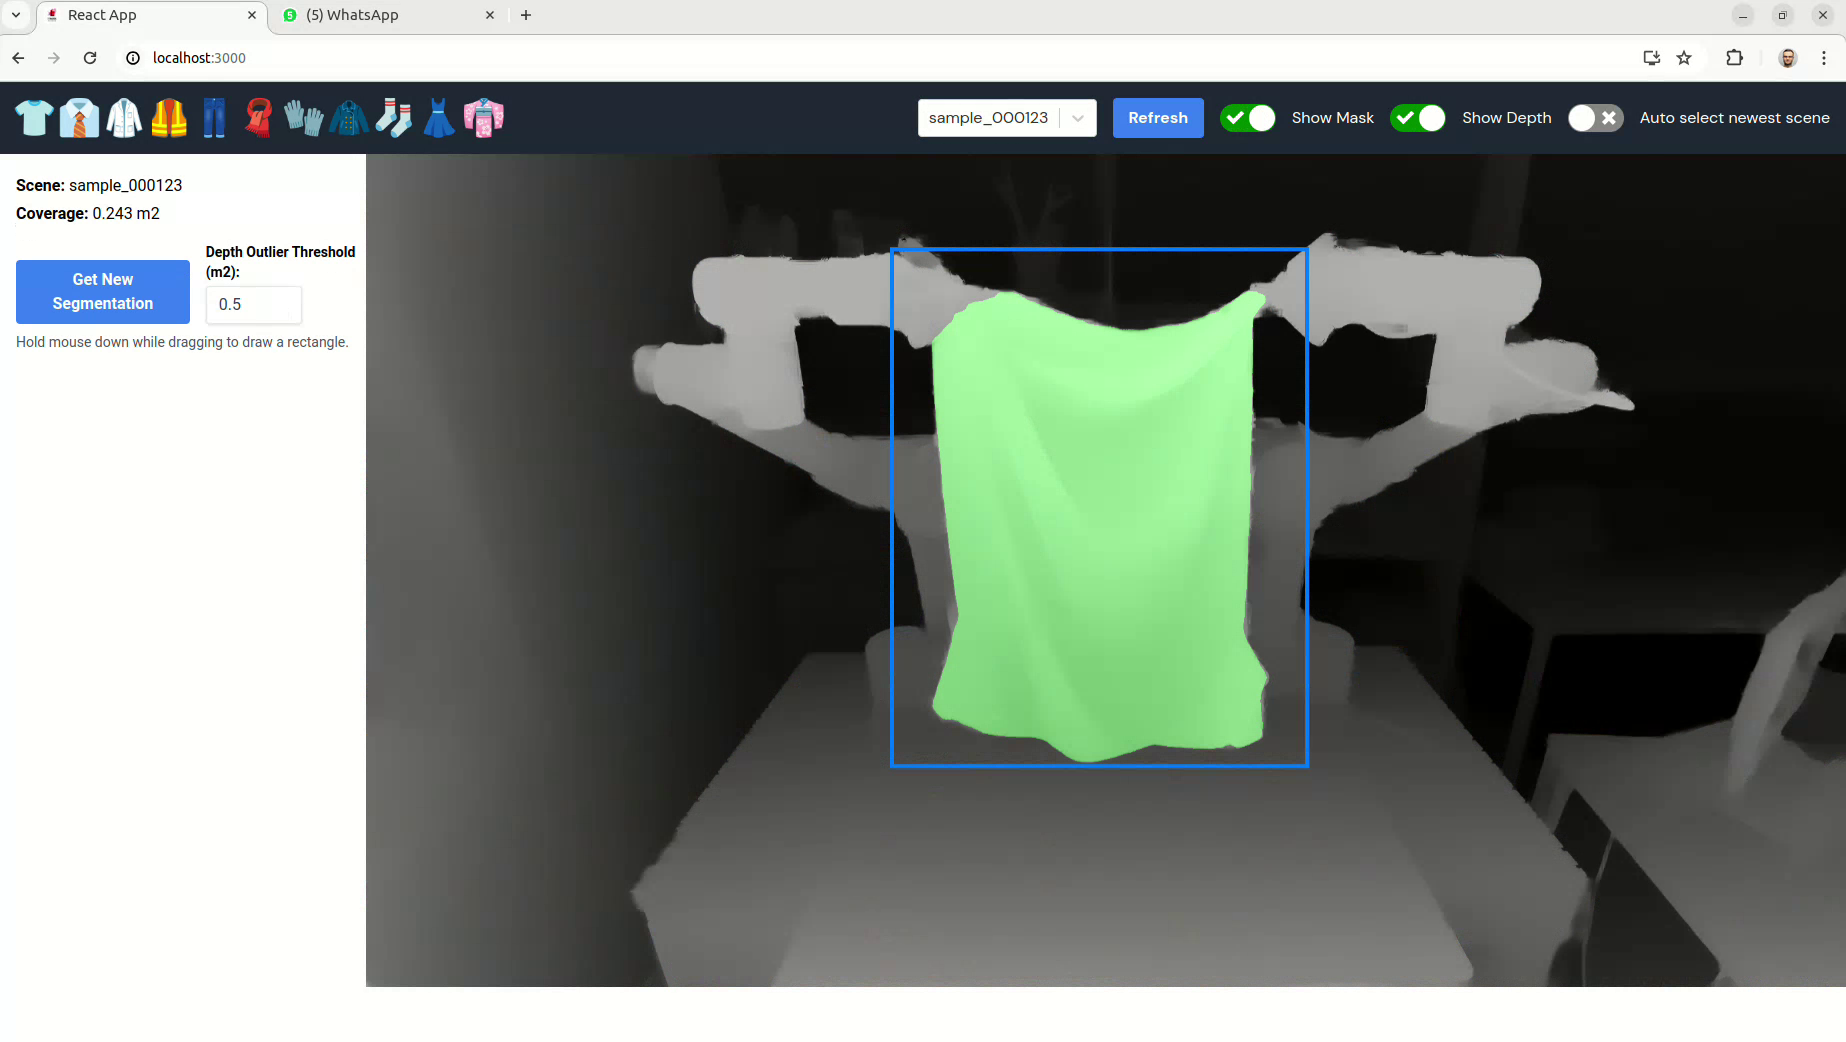
RGB Depth + mask
Measured: 0.243 m² Evaluation · IJRR 2026
Contributed to the ICRA 2024 Cloth Competition’s evaluation service: SAM-assisted segmentation, depth-based cloth coverage measurement, and dataset/server integration.
Co-author of the resulting benchmark and dataset paper.
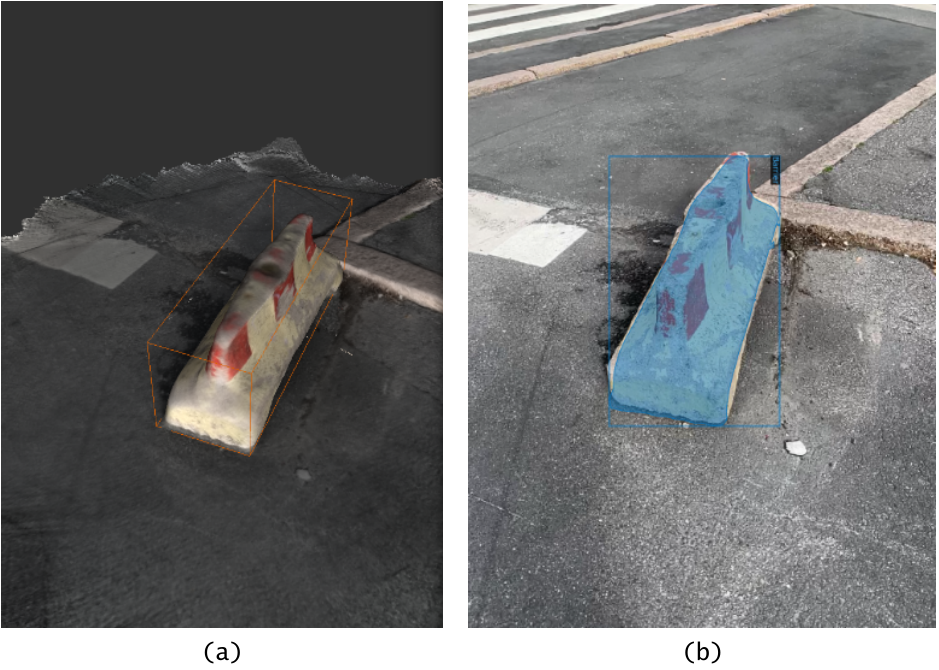
3D annotation Projected label Computer vision · Stray Robots
Co-founded Stray Robots and co-developed annotation tools combining RGB-D capture, SLAM, 3D reconstruction, and label projection.
Equal-contribution co-author of the 2021 preprint.
2026 The International Journal of Robotics Research
Co-author. Contributed to the competition’s evaluation tooling.
2022 IROS
First author. Best Paper, ABB Best Student Paper, and Best RoboCup Paper finalist.
2021 Preprint
Equal contribution with Kenneth Blomqvist.
tch-rs ↗ Tensor-expression fuser configuration binding for Rust. Merged upstream.
2023 crabnet ↗ Neural networks from scratch in Rust, with an illustrated tutorial.
2023 2022–present Nimble Robotics Reinforcement learning, policy deployment, and inference optimization.
2017–2022 Smartly.io Automated image and video generation, ad optimization, and ML product integration.
2021–2022 Stray Robots Computer vision tools for creating training data from RGB-D scans.
2020–2022 Aalto University Reinforcement learning and sim-to-real transfer for dynamic cloth manipulation.
I’m interested in developing and evaluating robot learning models through real-world experiments.
julius@juliushietala.com ↗ U.S. permanent resident